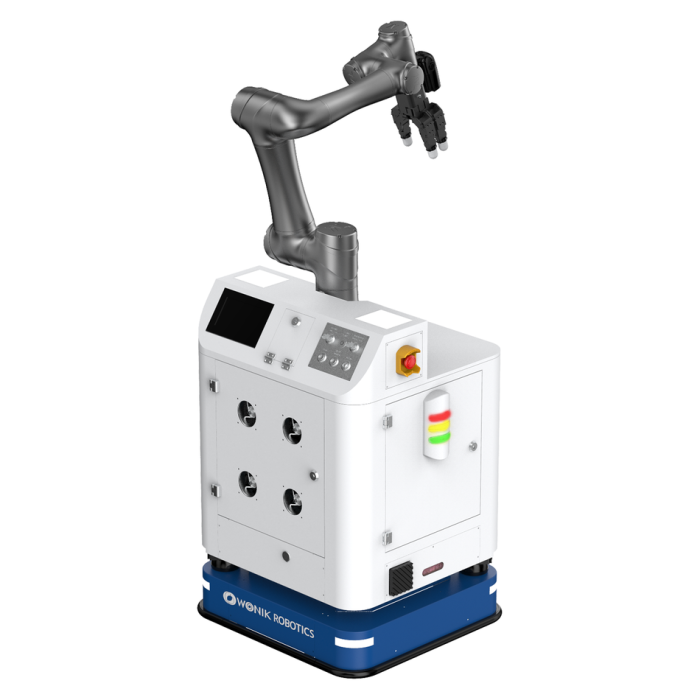
Wonik Robotics WR-AMMR05-3F
In stock
- ยี่ห้อ:
- Wonik Robotics
- รุ่น:
- WR-AMMR05-3F
- ส่วนที่ #:
- WR-AMMR05-3F
- Warranty:
- 12 เดือน
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Wonik-WR-AMMR05-3F
Wonik Robotics WR-AMMR05-3F
Wonik Robotics WR-AMMR05-3F Overview
The Wonik Robotics WR-AMMR05-3F is an autonomous mobile manipulation system that combines the WR-AMR mobile platform with a collaborative robot arm. According to the manufacturer, the configuration consists of the WR-AMR base with a Mecanum wheel drive, a TM-series robot arm, and an optional end effector. The unit is listed with a manipulator payload of 5 kg, a maximum travel speed of 1 m/sec, and a quoted operating time of 5 hours. The quoted runtime is a manufacturer figure and is not guaranteed under every load or duty cycle, since actual endurance depends on how the platform and arm are used.
Mobile Platform and Mobility
The mobile platform uses a Mecanum wheel driving system. The wheel set is described as urethane, with two 6-inch (15 cm) driving wheels and four sub wheels. Mecanum wheels allow a vehicle to translate and rotate in ways conventional wheels cannot, and the manufacturer's family material notes that Mecanum mobility supports directional changes and positioning in confined workspaces. The published dimensions are 654 x 700 x 1,470 mm (W x L x H), and the vendor explicitly identifies these as the dimensions of the mobile platform only. They do not describe the complete assembled robot with the arm and any end effector mounted, so facility planning should not treat 1,470 mm as the overall height of the full system.
Navigation is listed as SLAM (simultaneous localization and mapping), meaning the platform builds and uses a map of its environment to localize and move autonomously. The specification does not elaborate on the sensor suite behind the SLAM implementation, so no assumptions should be made about specific sensor types or mapping performance beyond the stated navigation type.
Manipulator and Payload
The manipulator is listed as a TechMann TM5-850 collaborative arm with a payload of 5 kg and a reach stated as 927.7 mm or 850 mm. The source presents these two reach figures as alternatives rather than a range, so the applicable reach value should be confirmed for the delivered configuration. Two distinct load figures appear in the specification and must not be conflated. The manipulator payload is 5 kg: this is the load the arm itself can handle. Separately, the robot's basic specification lists a payload of 100 kg (with manipulator): this describes the load capacity of the mobile platform while the manipulator is mounted. The 100 kg figure is not an arm payload and is not 100 kg of extra carrying capacity on top of other figures; it is the platform-level load rating as stated by the manufacturer.
Performance and Accuracy
The manufacturer lists a maximum speed of 1 m/sec and an average speed of about 0.5 m/sec. Two positioning figures are given: stop accuracy of ±10 mm for general stopping, and docking accuracy of ±1 mm. The tighter docking figure applies to docking operations, which is relevant where the platform must align repeatably with stations or fixtures; the ±10 mm stop accuracy is the more general positioning tolerance. As a planning consideration, achievable accuracy in a real deployment can be influenced by floor conditions and site setup, so the stated figures should be treated as manufacturer specifications rather than guarantees for every environment.
Battery and Charging
The battery is listed as Li-ion, DC50V / 50Ah. Charging time is quoted at about 2 to 2.5 hours, and the charging method supports both automatic and manual operation. The battery charging method is described as an automatic sliding-type charging and SWAP system, indicating that the design supports battery exchange in addition to in-place charging. The quoted 5-hour operating time should be read together with these figures: runtime depends on load, travel profile, and manipulator usage, so 5 hours is a reference value, not a guaranteed duration under all conditions.
Communication
Network connectivity is listed as WiFi at 2.4 GHz and 5 GHz with an external patch antenna, with optional support for LTE/5G. The optional cellular support may be a consideration for sites where WiFi coverage is inconsistent, though its availability for a given order should be confirmed.
Intended Application Context
The manufacturer's AMMR family page states that intended tasks for the family include material transport, assembly, palletizing, and machine tending. These are family-level contexts describing what the product line is designed around; they are not guaranteed turnkey applications of this exact configuration. Suitability for a specific task depends on the chosen end effector, workspace layout, and application engineering, which are deployment considerations rather than stated product capabilities.
Specification Summary
| Item | Specification |
|---|---|
| Navigation | SLAM |
| Dimensions (W x L x H) | 654 x 700 x 1,470 mm (mobile platform only) |
| Platform payload | 100 kg (with manipulator) |
| Manipulator | TechMann TM5-850, 5 kg payload, reach 927.7 mm or 850 mm |
| Drive | Mecanum wheels, urethane; driving 6 in (15 cm) x 2, sub x 4 |
| Speed | Max 1 m/sec; average about 0.5 m/sec |
| Accuracy | Stop ±10 mm; docking ±1 mm |
| Battery | Li-ion, DC50V / 50Ah; charging about 2–2.5 h; auto/manual; sliding-type charging and SWAP system |
| Network | WiFi 2.4/5 GHz with external patch antenna; optional LTE/5G |
| Operating time | 5 h (quoted; load dependent) |
Frequently Asked Questions
What payload can the WR-AMMR05-3F handle?
Two separate figures apply. The TM5-850 manipulator payload is 5 kg, which is the load the arm can handle. The mobile platform's payload is listed as 100 kg with the manipulator mounted, which is a platform-level load rating, not an arm payload and not additional arm capacity.
Do the listed dimensions describe the whole robot?
No. The vendor states that the 654 x 700 x 1,470 mm dimensions apply to the mobile platform only. The complete assembled system with the arm and any end effector mounted will differ, so overall clearance should be verified during planning.
What is the reach of the manipulator?
The source lists the TM5-850 reach as 927.7 mm or 850 mm. These are alternative values rather than a range, and the applicable figure should be confirmed for the specific configuration being supplied.
Is the end effector included by default?
The configuration lists the end effector as optional. The specification names the Allegro Hand V5 with a pressure sensor in the end-effect field, but this does not guarantee it is supplied by default; inclusion should be confirmed per order.
How long does the robot operate on a charge?
The manufacturer quotes an operating time of 5 hours. This is a reference figure and is not guaranteed under every load, since travel speed, carried load, and manipulator activity affect real-world endurance.
How is the battery charged?
The Li-ion DC50V / 50Ah battery charges in about 2 to 2.5 hours using automatic or manual charging. The system is described as an automatic sliding-type charging and SWAP system, which supports battery exchange as well as in-place charging.
What tasks is the AMMR family intended for?
The manufacturer's family page lists material transport, assembly, palletizing, and machine tending as intended task areas, with Mecanum mobility supporting positioning in confined workspaces. These are family-level contexts, not guaranteed turnkey applications of this exact unit; task fit depends on the end effector and application engineering.
What connectivity does it support?
WiFi at 2.4 GHz and 5 GHz with an external patch antenna is standard per the specification, and LTE/5G support is listed as optional.
Summary
The Wonik Robotics WR-AMMR05-3F pairs a Mecanum-wheel WR-AMR mobile platform using SLAM navigation with a TechMann TM5-850 collaborative arm rated for a 5 kg payload and a reach of 927.7 mm or 850 mm. The platform carries up to 100 kg with the manipulator mounted, travels at up to 1 m/sec, docks within ±1 mm, and runs on a swappable Li-ion DC50V / 50Ah battery with a quoted 5-hour operating time. The stated dimensions cover the mobile platform only, and the end effector is optional, so final configuration details should be confirmed against specific deployment requirements.
Request a quotation to confirm configuration, pricing and availability. Catalog stock status is not confirmation of physical inventory or immediate shipment.