Ti5 Robotics A3-0 Dual-Arm System
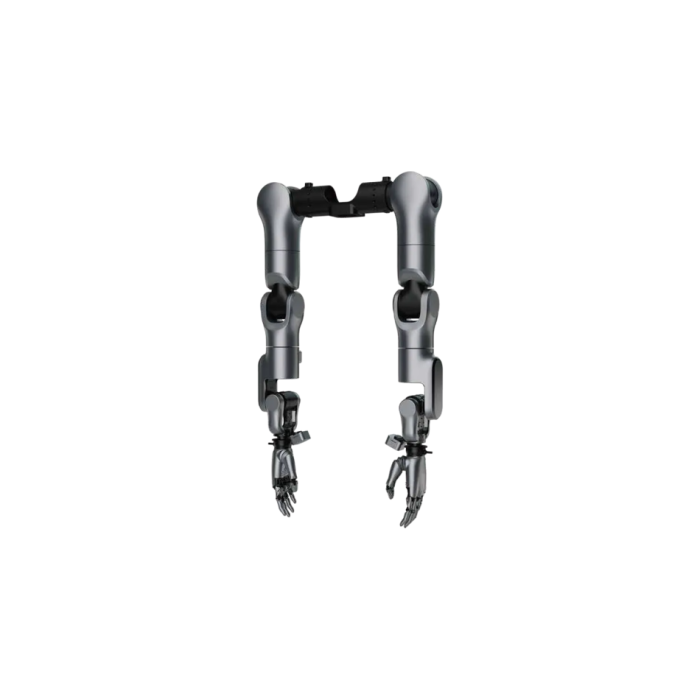
In stock
- MEREK:
- TI5 ROBOTICS
- MODEL:
- A3-0
- ORIGIN:
- Tiongkok
- Warranty:
- 12 BULAN
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Ti5-Robotics-A3-0
Ti5 Robotics A3-0 Dual-Arm System
Ti5 Robotics A3-0 Dual-Arm System is a lightweight, dual-arm manipulation platform developed by Ti5 Robotics for humanoid-robot integration, research, and advanced automation work. The standard configuration carries fourteen degrees of freedom across two seven-axis arms, a documented arm span of 1593 mm excluding hands (2032 mm including optional hands), and a gross weight of 15 kg. It is built from aluminum alloy and stainless steel structural elements with an ABS and fiberglass shell, and it is offered as a dual-arm standard product that can be extended with optional dexterous hands, force sensing, vision, batteries, and onboard computing.
Background
From joint modules to complete dual-arm systems
Ti5 Robotics specializes in the research, development, and manufacturing of intelligent robotic products and core components for humanoid robots, including lightweight joint modules, bionic hands, and collaborative arms. The A3-0 sits within the company's humanoid-robot product line as a complete dual-arm system rather than a single component: it combines fourteen joint motors with harmonic reducers, 18-bit joint encoders, and CAN/EtherCAT joint actuation into one integrated upper-body manipulation package. Although the vendor catalogs it under a humanoid actuator category, the A3-0 itself is a full dual-arm assembly intended for integration into larger robots or standalone manipulation setups.
Design philosophy of the A3-0
The A3-0 follows a modular, integration-first approach. The core deliverable is the dual-arm structure with internal structural component layout and a maximum arm circumference of 136 mm, keeping the profile slim enough for humanoid torsos and compact workcells. Around that core, Ti5 Robotics lists a series of optional subsystems — high-precision dexterous hands, dual six-dimensional force sensors at the arm ends, a 48 V 10 Ah battery, wrist-mounted Intel RealSense depth cameras, and an NVIDIA Jetson-class compute module — so integrators configure only what their application requires. A URDF-standard structural document is supplied after contract signing and before delivery, supporting simulation and motion-planning workflows from day one.
Technical Specifications
The following tables preserve the published configuration distinctions. Blank, malformed, or ambiguous source values are not confirmation of a capability; confirm the selected configuration during quotation.
Ti5 Robotics A3-0 Dual-Arm System
| Model | Ti5-A3-0 Dual-Arm Standard Product |
| Maximum arm circumference | 136mm |
| gross weight | 15kg |
| Structural component layout | Internal structural components |
| Arm span | 1593mm excluding hands / 2032mm including hands |
| Total number of degrees of freedom | 14 |
| Single-arm degree of freedom | 7 |
| Single-arm load | 3kg |
| Dexterous Hand Model (Optional) | High-precision dexterity hand |
| Dexterity of hand | 6 |
| Hand load | 3kg |
| Number of joint motors | 14 |
| Joint actuator type | CAN/EtherCAT |
| Joint reducer type | harmonic |
| Joint encoder resolution | 18bit |
| Dual-arm end effector (optional) | Six-dimensional force *2 Model: Yuli M3552D1 with M8123B2 and 232 communication interface |
| Battery capacity and voltage (optional) | 48 V10Ah |
| Visual perception (optional) | Intel RealSense D4 wrist depth camera05*2 |
| Communication Protocol | Joint CAN/EC, Hand 485/CAN |
| Control and computing power (optional) | Jeston Orin Nano 8G*1 (Upgradeable to Jeston AGx Orin 64G Developer Kit, optional) |
| Structural materials | Aluminum alloy, stainless steel, etc. |
| Shell material | ABS + fiberglass, etc. |
| Structural related | URDF standard format document (output after contract signing and before complete machine delivery) |
| Software Algorithm | Dual-arm API, including interfaces for joint movement, pose adjustment, and obtaining motor positions. |
How does the A3-0 handle control and integration?
The A3-0 exposes its joints over CAN and EtherCAT, the two bus standards most widely used in high-performance robot actuation, while optional dexterous hands communicate over 485/CAN. Ti5 Robotics supplies a dual-arm API covering joint movement commands, pose adjustment, and reading back motor positions, giving developers direct programmatic access to the full fourteen-axis kinematic chain. The optional Jetson Orin Nano 8G module provides onboard computing for perception and control, and can be specified as the larger Jetson AGX Orin 64G Developer Kit where heavier AI workloads — such as vision-language-action models or dual-camera depth processing — are planned. The URDF document delivered with each contract allows the system to be modeled accurately in common simulators before hardware arrives.
Who is the A3-0 for?
The A3-0 is aimed at humanoid-robot developers who need a ready-made upper body, research laboratories studying bimanual manipulation and imitation learning, universities equipping robotics programs, and automation integrators prototyping two-handed tasks that single-arm cobots cannot perform. Its 3 kg per-arm payload, seven-axis redundancy, and 15 kg system weight make it practical for teams that want human-like reach and dexterity without engineering a dual-arm mechanism from individual actuators. Buyers who prefer to build from components can instead source Ti5's joint modules, but the A3-0 serves those who want an integrated, documented platform.
What is the A3-0 used for?
- Humanoid-robot development, where the dual-arm assembly forms the upper limbs of a larger platform.
- Bimanual manipulation research, including coordinated two-handed grasping and handover studies.
- Teleoperation and data-collection rigs for training manipulation and imitation-learning models.
- Scientific research and education, consistent with the vendor's stated application areas.
- Prototyping of industrial and commercial two-armed tasks such as sorting, assembly studies, and service scenarios.
- Perception-driven experiments combining optional wrist depth cameras, force sensing, and onboard Jetson computing.
Pricing and Availability
The Ti5-A3-0 is configured to order, and final pricing depends on the options selected — dexterous hands, six-dimensional force sensors, battery, cameras, and compute module all affect the quotation. Request a quote through this listing to receive current pricing, configuration guidance, and lead-time information for your region and intended use.
Frequently Asked Questions
How many degrees of freedom does the A3-0 have?
Fourteen in total — seven per arm — driven by fourteen joint motors with harmonic reducers and 18-bit encoders. Optional dexterous hands add six degrees of freedom of hand dexterity each.
What payload can each arm carry?
Each arm is rated for a 3 kg load, and the optional high-precision dexterous hand is likewise specified for a 3 kg hand load.
Are the hands, cameras, and computer included?
No. The dexterous hands, six-dimensional force sensors, 48 V 10 Ah battery, wrist depth cameras, and Jetson compute module are all listed as optional and must be specified at ordering time.
Which communication protocols does it use?
Joints communicate over CAN and EtherCAT; optional hands use 485/CAN. Optional force sensors use a 232 communication interface.
Does Ti5 Robotics provide software support?
Yes. A dual-arm API is supplied with interfaces for joint movement, pose adjustment, and obtaining motor positions, plus a URDF-format structural document delivered after contract signing and before machine delivery.
How large and heavy is the system?
Arm span is 1593 mm excluding hands or 2032 mm including hands, maximum arm circumference is 136 mm, and gross weight is 15 kg.
Where can I buy the A3-0 and what does it cost?
You can purchase the Ti5-A3-0 dual-arm system through this listing. Because pricing varies with the optional hands, sensors, battery, cameras, and compute configuration, submit a quote request to receive an itemized price and delivery estimate.
Summary
The Ti5 Robotics A3-0 is an integrated fourteen-axis dual-arm system that pairs harmonic-drive joints, high-resolution encoders, and CAN/EtherCAT control with a modular menu of optional hands, sensing, power, and computing. For teams building humanoid robots or researching bimanual manipulation, it offers a documented, API-supported platform without component-level integration work. To evaluate configurations and request a quotation, this page is the starting point.