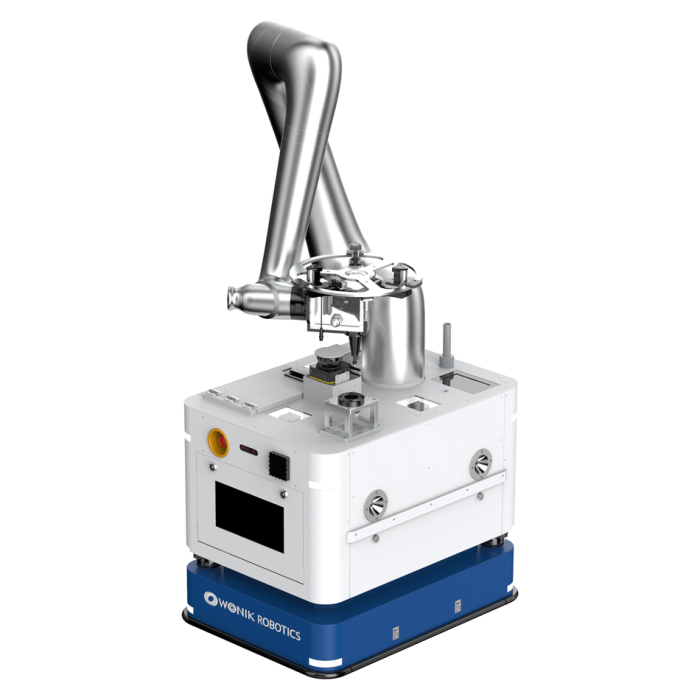
Wonik Robotics WR-AMMR20-CT
In stock
- MEREK:
- Wonik Robotics
- MODEL:
- WR-AMMR20-CT
- BAGIAN #:
- WR-AMMR20-CT
- Warranty:
- 12 BULAN
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Wonik-WR-AMMR20-CT
Wonik Robotics WR-AMMR20-CT
Overview
The Wonik Robotics WR-AMMR20-CT is an autonomous mobile manipulation robot that combines the Wonik WR-AMR mobile platform with a NEUROMEKA Nuri20 collaborative robot arm. According to the manufacturer, the AMMR family integrates an autonomous mobile robot, a collaborative robot and an end effector, with intended task areas that include material transport, assembly, palletizing and machine tending. These are family-level contexts rather than guaranteed turnkey applications of this exact configuration. The platform uses mecanum wheel drive and SLAM navigation, and is specified with a 20 kg manipulator payload, a 1 m/sec maximum speed and a quoted 5-hour operating time.
Configuration and System Architecture
The listed configuration consists of three elements: the WR-AMR mobile base with mecanum wheels, a NEUROMEKA robot arm, and an end effector that the manufacturer lists as optional. The specification names a Quartz Gripper under the end effect item, but because the end effector is explicitly optional in the configuration, the gripper should not be assumed to be supplied by default and inclusion should be confirmed when specifying a system.
The manipulator is the NEUROMEKA Nuri20, with a stated payload of 20 kg and a stated reach of 1,798 mm. Mounting a collaborative arm on a mobile base allows one unit to combine transport with handling at the destination, which is the core concept of the AMMR family as described by the manufacturer.
Mobility and Drive System
The WR-AMMR20-CT uses a mecanum wheel driving system. Mecanum wheels allow a vehicle to translate in any direction and rotate in place, and the manufacturer notes that this mobility supports directional changes and positioning in confined workspaces. The wheel set is urethane, with two 6-inch (15 cm) driving wheels and four sub wheels. Maximum speed is 1 m/sec and average speed is stated as about 0.5 m/sec, which is a more realistic reference for cycle-time planning than the peak figure alone.
Payload: Manipulator Capacity Versus Platform Load
The specification lists two payload figures that describe different things, and they should not be combined.
- The manipulator payload is 20 kg. This is the capacity of the Nuri20 arm itself and applies to objects the arm lifts and handles.
- The platform payload is 100 kg with the manipulator. This figure describes the mobile platform's load in that configuration; it is not the arm's lifting capacity and should not be read as 100 kg of additional free cargo capacity.
In practice, the arm handles items up to its 20 kg rating, while the 100 kg figure is the vendor's statement of platform loading with the manipulator installed; plans that assume extra deck cargo should be confirmed with the manufacturer.
Navigation and Positioning Accuracy
Navigation is based on SLAM (simultaneous localization and mapping). Two accuracy figures are published: a stop accuracy of ±10 mm for general positioning, and a docking accuracy of ±1 mm. The tighter docking figure indicates that precise alignment is achieved at defined docking positions rather than everywhere in free space, so precision-dependent manipulation is typically planned around docked positions.
Dimensions
The stated dimensions are 700 x 950 x 810 mm (W x L x H), and the manufacturer qualifies these as the dimensions of the mobile platform only. The complete assembled robot with the Nuri20 arm installed is not described by these figures, so aisle widths, door clearances and overhead obstructions should be assessed against the assembled configuration as a planning consideration.
Power, Battery and Charging
The robot uses a lithium-ion battery rated DC 50 V / 50 Ah. The quoted operating time is 5 hours; actual runtime depends on duty cycle and load, so this figure should not be treated as guaranteed under every condition. Charging takes about 1 to 1.5 hours, with automatic and manual charging methods supported. The battery charging method is described as an automatic sliding-type charging and SWAP system, meaning the design supports both recharging in place and battery exchange.
Connectivity
Network connectivity is provided over Wi-Fi at 2.4 GHz and 5 GHz with an external patch antenna. The manufacturer lists optional support for LTE/5G, which should be specified at order time if cellular connectivity is required.
Key Specifications
| Item | Specification |
|---|---|
| Navigation type | SLAM |
| Dimensions (W x L x H) | 700 x 950 x 810 mm (mobile platform only) |
| Platform payload | 100 kg (with manipulator) |
| Manipulator | NEUROMEKA Nuri20, 20 kg payload, 1,798 mm reach |
| Driving system | Mecanum wheel; urethane, driving 6 in (15 cm) x 2, sub x 4 |
| End effector | Optional; Quartz Gripper named in specification |
| Stop accuracy | ±10 mm |
| Docking accuracy | ±1 mm |
| Maximum speed | 1 m/sec |
| Average speed | About 0.5 m/sec |
| Battery | Li-ion, DC 50 V / 50 Ah |
| Charging time | About 1 to 1.5 hours |
| Charging method | Auto / manual; automatic sliding-type charging and SWAP system |
| Operating time | 5 hours (quoted; load dependent) |
| Network | Wi-Fi 2.4 / 5 GHz with external patch antenna; optional LTE/5G |
Application Context and Planning Considerations
The manufacturer describes the AMMR family as intended for material transport, assembly, palletizing and machine tending; for this configuration those applications are context, not guaranteed turnkey capabilities. Relevant planning considerations include confirming that target parts fall within the 20 kg arm payload and 1,798 mm reach, verifying clearances against the assembled robot rather than platform-only dimensions, and matching recharge or battery-swap workflows to shift patterns. These are general engineering considerations, not additional product capabilities.
Frequently Asked Questions
What is the Wonik Robotics WR-AMMR20-CT?
It is an autonomous mobile manipulation robot combining the mecanum-wheel WR-AMR platform with a NEUROMEKA Nuri20 collaborative arm. The manufacturer positions the AMMR family for material transport, assembly, palletizing and machine tending contexts.
How much can the WR-AMMR20-CT lift?
The Nuri20 manipulator is rated for a 20 kg payload. Separately, the platform is specified at 100 kg payload with the manipulator installed; that figure is not the arm's capacity and does not mean 100 kg of extra cargo capacity.
Is a gripper included by default?
The end effector is listed as optional. Although the specification names a Quartz Gripper, inclusion is not guaranteed, so the end effector should be confirmed when configuring a system.
How long does it run on a charge?
The quoted operating time is 5 hours, with charging taking about 1 to 1.5 hours. Actual runtime varies with load and duty cycle, so the 5-hour figure is not guaranteed under every condition. A battery SWAP system is also supported alongside automatic sliding-type charging.
How accurate is its positioning?
Published figures are ±10 mm stop accuracy for general positioning and ±1 mm docking accuracy at defined docking positions, where precision-dependent tasks are typically planned.
Do the listed dimensions describe the whole robot?
No. The 700 x 950 x 810 mm figure applies to the mobile platform only; the complete robot with the arm installed is not described by it, so clearances should be checked against the assembled configuration.
What connectivity does it offer?
Standard connectivity is Wi-Fi at 2.4 GHz and 5 GHz with an external patch antenna. LTE/5G support is optional and must be specified if required.
Summary
The Wonik Robotics WR-AMMR20-CT pairs a mecanum-wheel WR-AMR platform with a NEUROMEKA Nuri20 arm offering 20 kg payload and 1,798 mm reach, SLAM navigation with ±1 mm docking accuracy, a DC 50 V / 50 Ah Li-ion battery with a quoted 5-hour runtime and swap-capable charging, and Wi-Fi with optional LTE/5G. Its platform-only dimensions, optional end effector and clearly separated manipulator and platform payload figures are the key points to verify when evaluating it for transport and handling tasks.
Request a quotation to confirm configuration, pricing and availability. Catalog stock status is not confirmation of physical inventory or immediate shipment.