Elephant Robotics myGripper H100 Left Hand (4010700101)
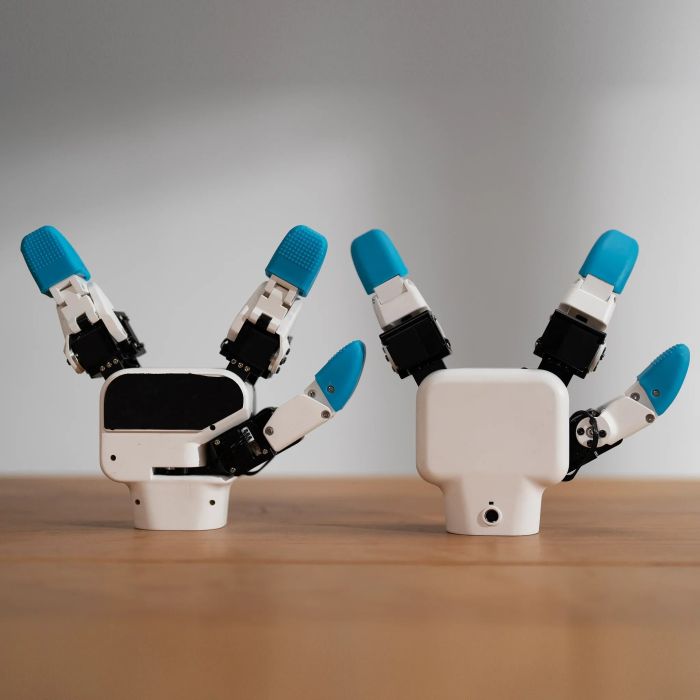
Elephant Robotics myGripper H100 is a three-finger dexterous robotic hand for myCobot Pro 630 and Mercury series platforms. It supports 500 g payloads, RS485/MODBUS communication, Python, ROS, and real-time grasping data collection.
In stock
- ᲑᲠᲔᲜᲓᲘ:
- ELEPHANT ROBOTICS
- ᲛᲝᲓᲔᲚᲘ:
- myGripper H100
- ᲜᲐᲬᲘᲚᲘ #:
- 4010700101
- ORIGIN:
- ჩინეთი
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Elephant Robotics Technology-4010700101
899,00 US$
Elephant Robotics myGripper H100
The myGripper H100 is a three-finger dexterous robotic hand developed by Elephant Robotics for robotics research, education, laboratory demonstrations, and precise manipulation tasks. It is designed for the myCobot Pro 630 and Mercury series platforms, using six high-performance digital servo motors to support torque, speed, and absolute-position control.
Official Elephant Robotics myGripper H100 product video
Key Capabilities
- Three-finger dexterous grasping for tools, food, fruit, and laboratory objects.
- Six movable joints for hand-like movements and gesture demonstrations.
- Ten adjustable torque levels with a load adjustment range up to 500 g.
- 100 Hz high-frequency communication for real-time grasping status monitoring.
- Open serial-port and motor-control protocols for secondary development.
- Python support with ROS1, ROS2, and RViz simulation workflows.
Specifications
- Payload: 500 g
- Self-weight: 780 g
- Stroke diameter: 0-130 mm
- Motion speed: 60 degrees per second per joint
- Fingers: 3
- Movable joints: 6
- Motor type: servo motor supporting current, position, and speed control
- Lifespan: 1,000,000 cycles or more
- Electrical interface: M8 Pin aviation connector
- Power: 24 V, 2 A
- Communication interface: RS485
- Communication speed: above 50 Hz; product page notes 100 Hz high-frequency communication
- Protocol: MODBUS; data format Hex, 8N1
- Main control chip: ESP32, 240 MHz dual-core, 600 DMIPS, 520 KB SRAM, Wi-Fi, dual-mode Bluetooth
- Compatible models: myCobot Pro 630 and Mercury series
Package Contents
- Three-finger dexterous hand
- Dual-head 8-pin aviation connector cable
- Extension cable
- USB to 485 module
- 8-pin aviation connector with 2 m extension cable
- USB data cable
Specifications
General
ᲑᲠᲔᲜᲓᲘ
ELEPHANT ROBOTICS
ᲛᲝᲓᲔᲚᲘ
myGripper H100
ᲜᲐᲬᲘᲚᲘ #
4010700101
ᲠᲝᲑᲝᲢᲘᲡ ᲢᲘᲞᲘ
ᲙᲝᲑᲝᲢᲘ
Write a Review